Jev solving a micromouse maze
Jev, by TypeSafe AI, answers closed questions with a probability. I put it in charge of Ratatron, my micromouse, to see if it can solve a maze.
Jev, by TypeSafe AI, answers closed questions with a probability. I put it in charge of Ratatron, my micromouse, to see if it can solve a maze.
Ratatron is my micromouse: a small robot that has to find its way to the centre of an unknown maze, work out the fastest route and then run it as fast as it ...
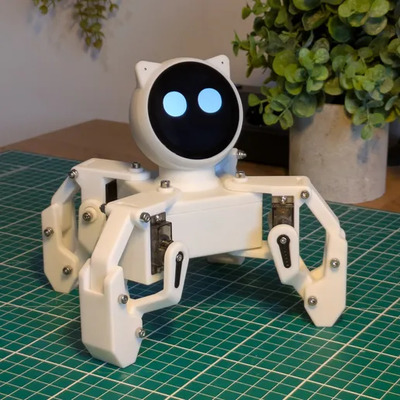
In this post I’m sharing a concept project that combines my Kame32 robot with Espressif’s EchoEar conversational device by redesigning the robot’s top cover ...
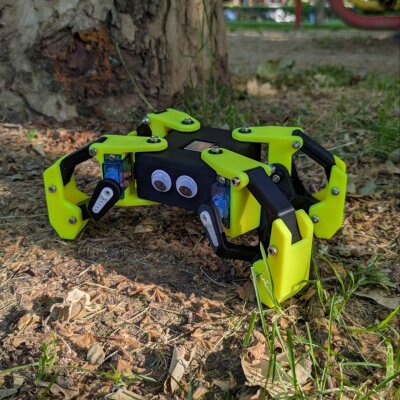
I’m excited to introduce Kame32, a completely redesigned version of the original Minikame robot I created back in 2016. This new version features a much more...
Abrelatas is my 1lb combat robot, built in 2023 for the robot combat tournament at OSHWDem. It’s a 4-wheel drive vertical spinner, mostly 3D printed.
Pandatron is a line-following robot I built back in 2017 as my first step into the world of line-follower competitions. Two years before, I teamed up with Ru...
Zowi is a small, open-source, 3D-printable biped robot I created back in 2015 while working at BQ’s innovation lab. It was fully designed in FreeCAD, using c...
Maus is a five-degree-of-freedom biped robot I built as a test platform for my master’s thesis on oscillator-based locomotion for legged robots, at Universid...
Minikame is a quadruped robot with 8 degrees of freedom that I designed in 2016 while working at the innovation lab of the now-defunct Spanish company BQ. At...
Micropanda is a microsumo robot I built in 2019: two robots inside a ring, and the first one to push the other out wins. In microsumo the robot must fit in a...
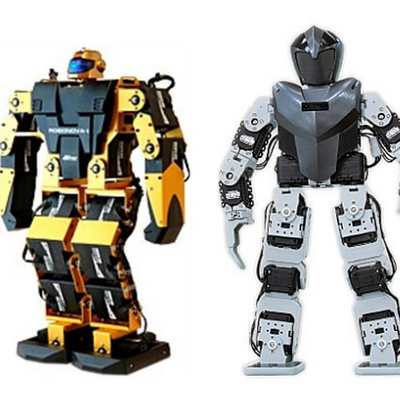
The most common way to build the legs of a humanoid robot, and why it overloads the knee servo.
Raider won both humanoid tests at Cosmobot 2016 in Barcelona: the one metre sprint and weightlifting.
A humanoid prototype I built to experiment with unusual leg configurations, with knees driven by two servos in parallel.
Zowi with two arms and a head: a micro humanoid to learn how to move many servos at once. Step by step assembly guide.
Twimaro (Twin Manipulator Robots) is a pair of twin robotic arms: if you move one of them by hand, the other one copies the movement. I built it in 2015 as a...
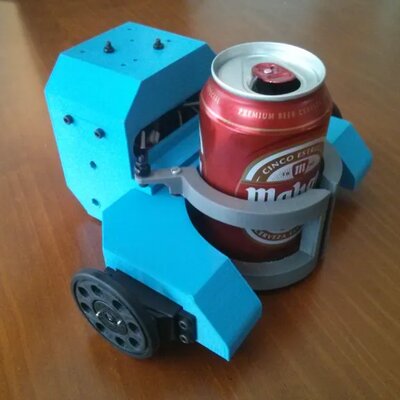
Beerbot (Beer Extraction Experimental Robot) is a small mobile robot that finds a can, grabs it and brings it back to where it started, avoiding the obstacle...
Este post es una copia del original escrito por mi y publicado el 07/04/2015 en la plataforma DIWO de BQ
A 3D printed pan-tilt turret that tracks targets of different colours with a webcam and points a laser at them. A computer vision project from my master’s.
Erizos bailones (dancing hedgehogs) is a table with a matrix of 32 neodymium magnets that move up and down, each one driven by a servo. Around every magnet t...
Raider is a competition humanoid with 24 degrees of freedom. Its name stands for Robot Antropomórfico para la Investigación y Desarrollo en Entornos Reales. ...