Predator
Predator is a humanoid robot prototype that I used to experiment with unusual leg configurations.
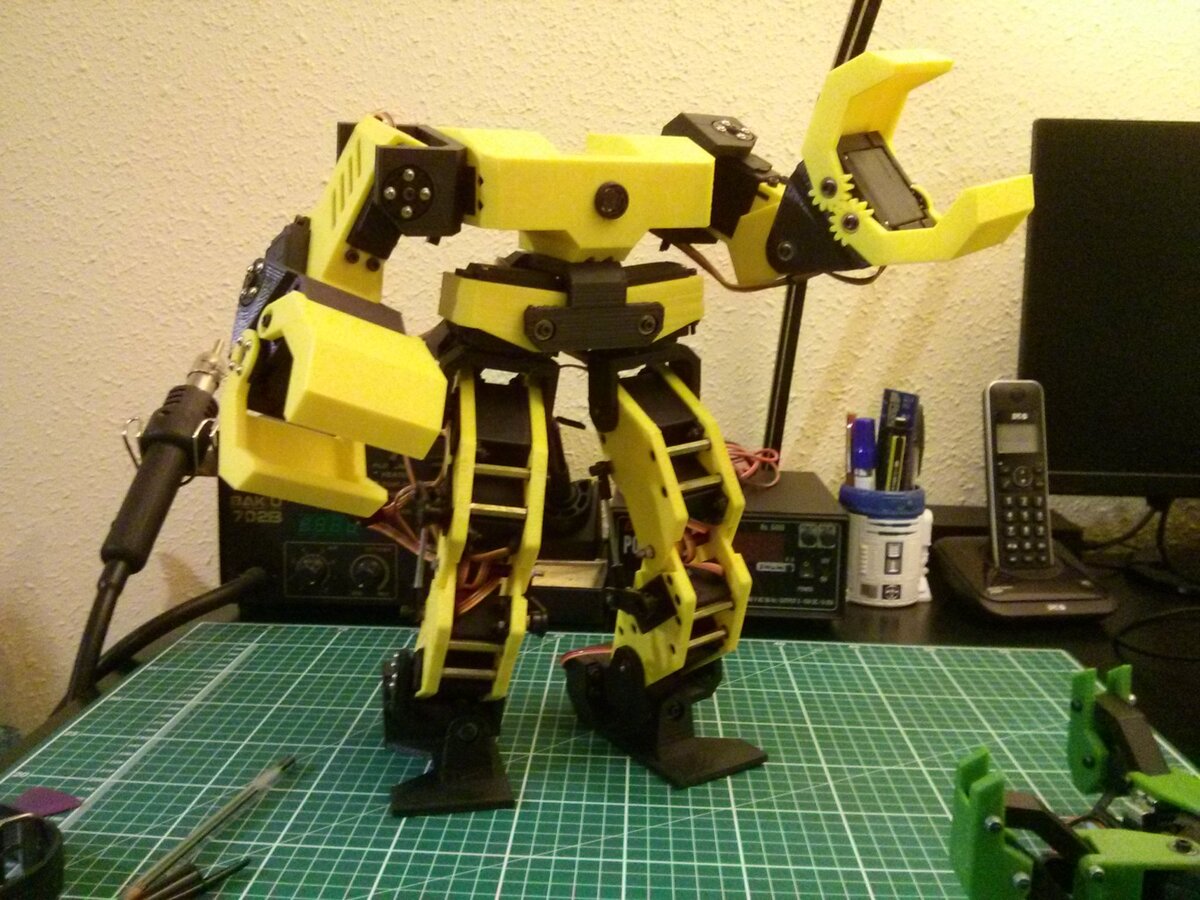
Most humanoids chain one servo after another along the leg, using the shaft of each servo as the joint. In that configuration the knee servo has to move twice as much as the hip and ankle every time the leg stretches or bends, and it’s also the one carrying most of the weight. Predator tries other ways around that:
- Knees: each knee is driven by two servos placed in parallel, which transmit their movement through ball joints and metal links.
- Hips: the roll movement of the hips comes from two servos placed in an inverted V behind the legs.
- Body: three more servos, one for the yaw of the hip and two for the pitch of the arms.
I never got to power up the whole robot, because projects keep piling up, but I tested each limb on its own with good results.
Comments